Ahmed Elbary Profile Picture

Ahmed Elbary

Robotics & Mechatronics Engineer
ROS2 | Autonomous Systems | Computer Vision | Safety Standards
Lincoln, United Kingdom

I'm an MSc Robotics graduate and Mechatronics Engineer based in the United Kingdom, passionate about building intelligent robotic systems that combine software, electronics, and artificial intelligence to solve real-world engineering challenges.

What excites me most is bringing ideas to life from developing autonomous navigation software and computer vision applications to designing embedded systems that interact with the physical world. I enjoy solving engineering problems by integrating hardware and software into practical, reliable solutions.

I'm currently seeking opportunities in Robotics, Autonomous Systems, Computer Vision, and Embedded Software Engineering, where I can continue contributing to innovative projects. This portfolio showcases the projects, technical skills, and experiences that have shaped my engineering journey so far.
Projects

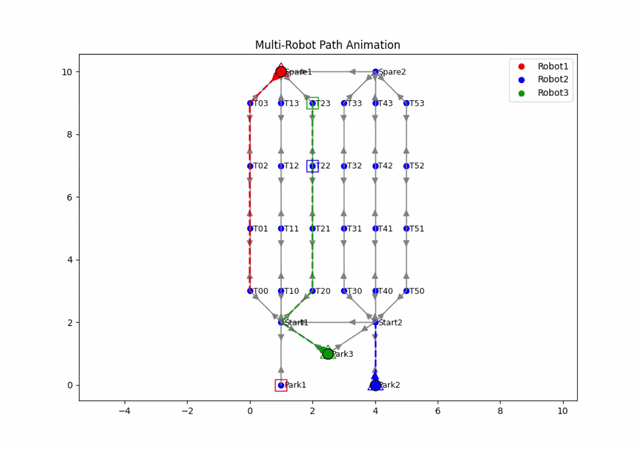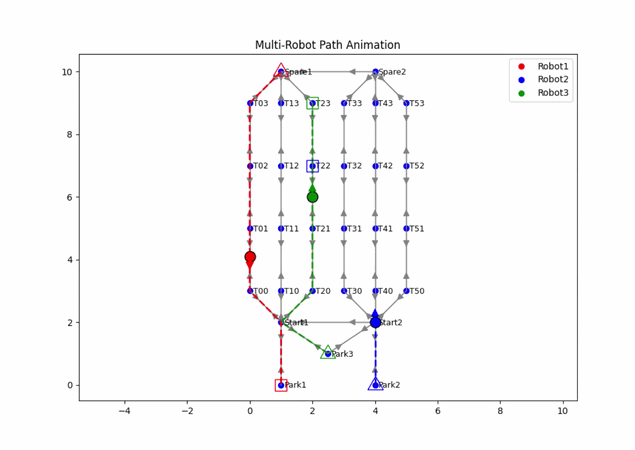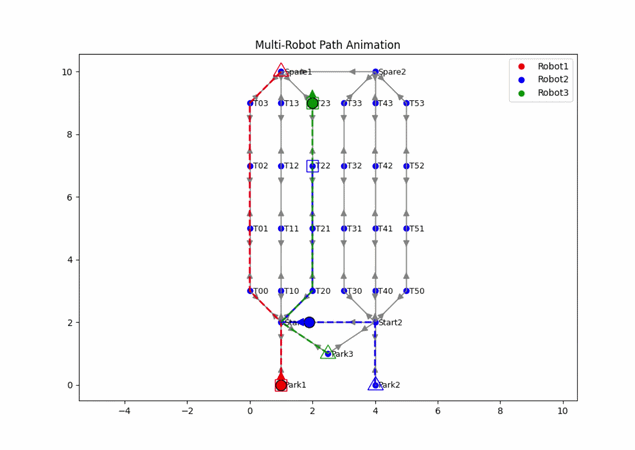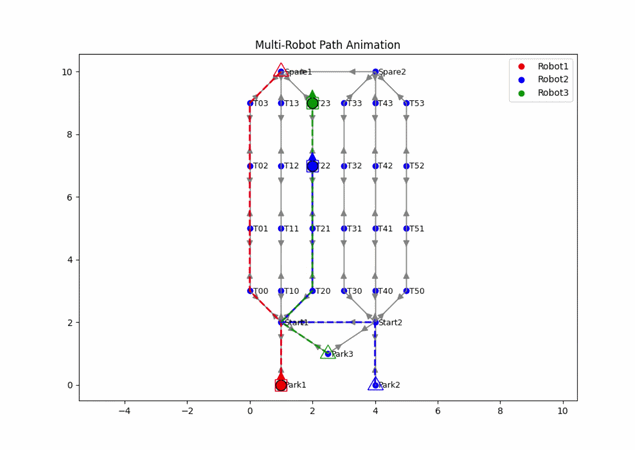
Multi-Robot Path Planning Simulation

Multi-Robot Space-Time Path Planning

Master's Project @ University of Lincoln

June 2025 - September 2025

The Challenge

Coordinating multiple autonomous robots within shared environments is a complex planning problem. Robots must reach their destinations safely while avoiding collisions, deadlocks, and unnecessary waiting at shared junctions. The challenge was to improve overall coordination while maintaining efficient paths for every robot.

My Contributions

For my Master's dissertation, I independently designed and developed a Space-Time Planner that extends an existing Fragment Planner by incorporating temporal awareness into the planning process. To evaluate both approaches fairly, I built a complete Python simulation framework capable of running, visualising, and comparing the behaviour of both planners under identical conditions.

Results

The proposed planner successfully improved robot coordination by reducing waiting time, shortening travel distances, and producing smoother overall navigation compared with the original Fragment Planner. The project demonstrated how scheduling information can significantly improve multi-robot path planning performance in shared environments.

ROS2 Python Simulation Git Multi-Robot Path Planning
Autonomous Agricultural Robot

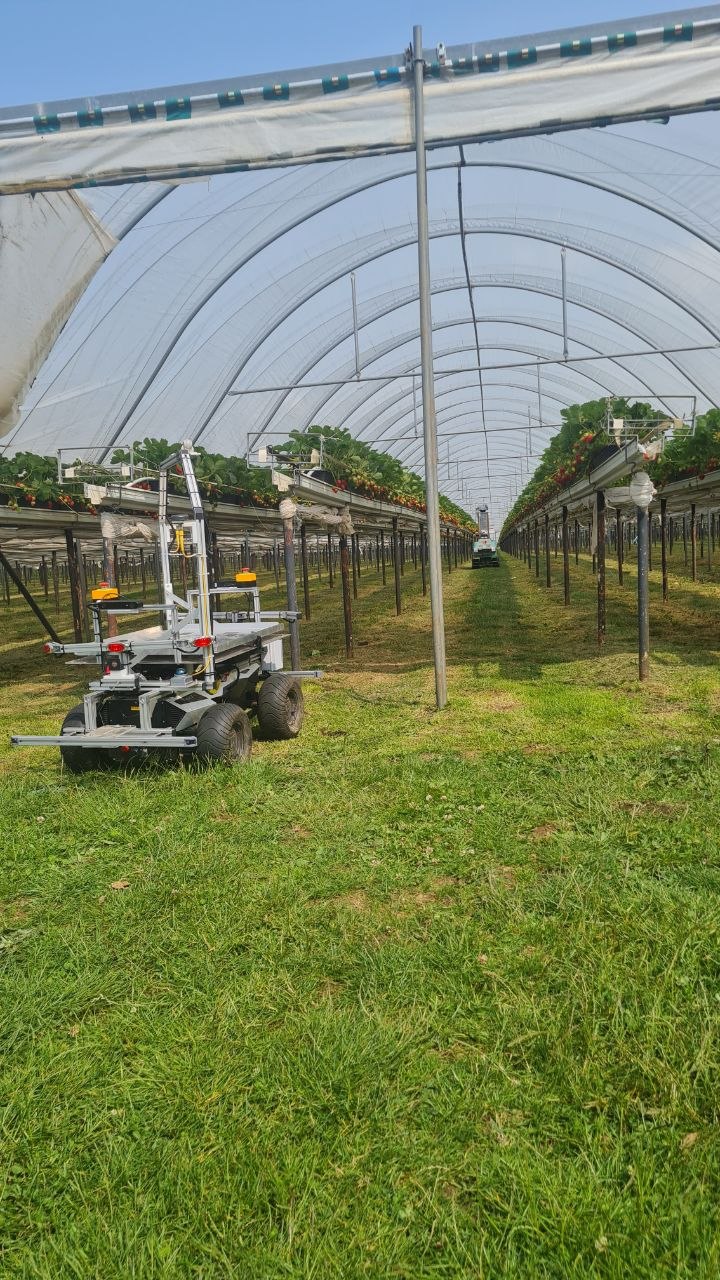
Safety System for Agricultural Robots

JABAS.AI @ University of Lincoln

March 2025 - July 2025

During my MSc in Robotics at the University of Lincoln, I worked on the IRoN-RAS research project in collaboration with JABAS.AI as part of the Lincoln Centre for Autonomous Systems (LCAS). I contributed to the software integration and safety systems of an autonomous agricultural robot designed for real-world field environments.

My Contributions

  • Developed and integrated ROS2 software modules for the autonomous robot platform.
  • Implemented and tested obstacle detection and emergency stop functionality.
  • Integrated hardware and software safety features, including bumper sensors and audiovisual warning systems.
  • Applied robotics safety standards, including ISO 12100, ISO 13849 and ISO 18497, during system integration and testing.
  • Collaborated with a multidisciplinary team to support hardware–software integration for field deployment.
ROS2 Python Ubuntu Git LiDAR Safety Standards

My Journey

My academic journey has taken me from Malaysia to the United Kingdom, where I built a strong engineering foundation before specialising in robotics.

🇲🇾 Malaysia

Universiti Teknologi Malaysia

BEng Electrical-Mechatronics Engineering

2017 - 2022

  • Built a strong foundation in Electronics Engineering.
  • Studied Embedded Systems, Control Engineering and Automation.
  • Developed a passion for intelligent robotic systems.

✈️

Moved to the UK

To specialise in Robotics & AI

🇬🇧 United Kingdom

University of Lincoln

MSc Robotics & AI

2024 - 2025

  • Specialised in Robotics and Autonomous Systems.
  • Focused on path planning, intelligent algorithms and software development.
  • Completed a Master's dissertation on Multi-Robot Path Planning.

Technical Skills

Throughout my academic and personal projects, I have developed experience across robotics, software development, artificial intelligence and electronics engineering.

Programming


Python C++ MATLAB Git & GitHub Linux (Ubuntu)

Robotics


ROS 2 Gazebo RViz Navigation2 SLAM

Artificial Intelligence


Computer Vision Machine Learning Path Planning Autonomous Systems

Engineering


Embedded Systems Electronics Control Systems SolidWorks

Certifications

These certifications reflect my continuous professional development and commitment to staying current with the latest advancements in robotics, autonomous systems, and related technologies.